Addressing The Demand For High Torque Density Actuators In Medical Robotics
Medical robotics developers face a persistent engineering challenge: achieving high torque density, precision, and compact footprints within micro-manipulation systems. Devices such as micro-surgical robots and fluid transmission systems require actuation components that deliver substantial torque while remaining small enough for integration into sensitive, space-constrained assemblies. VAXOR-MOTOR, operating under the brand VAXOR, positions itself as a provider of integrated micro-actuation solutions, specializing in axial flux motors, cycloidal gear reducers, and non-contact encoder integration—directly addressing this industry pain point.
Why Torque Density Matters For Medical Applications
In medical robotics, particularly micro-surgical systems, the ability to generate strong continuous and peak torque within a small diameter is a defining performance requirement. VAXOR's core value proposition centers on achieving high torque density and rigidity through the integration of axial flux motors and micro cycloidal reducers. Its electromagnetic designs optimize phase imbalance to within 5%, which supports high yield and power density—factors that are critical when medical device manufacturers require consistent, reliable performance across production batches.
VAXOR's Technology Platform For High Torque Density Actuation
Core Technical Metrics
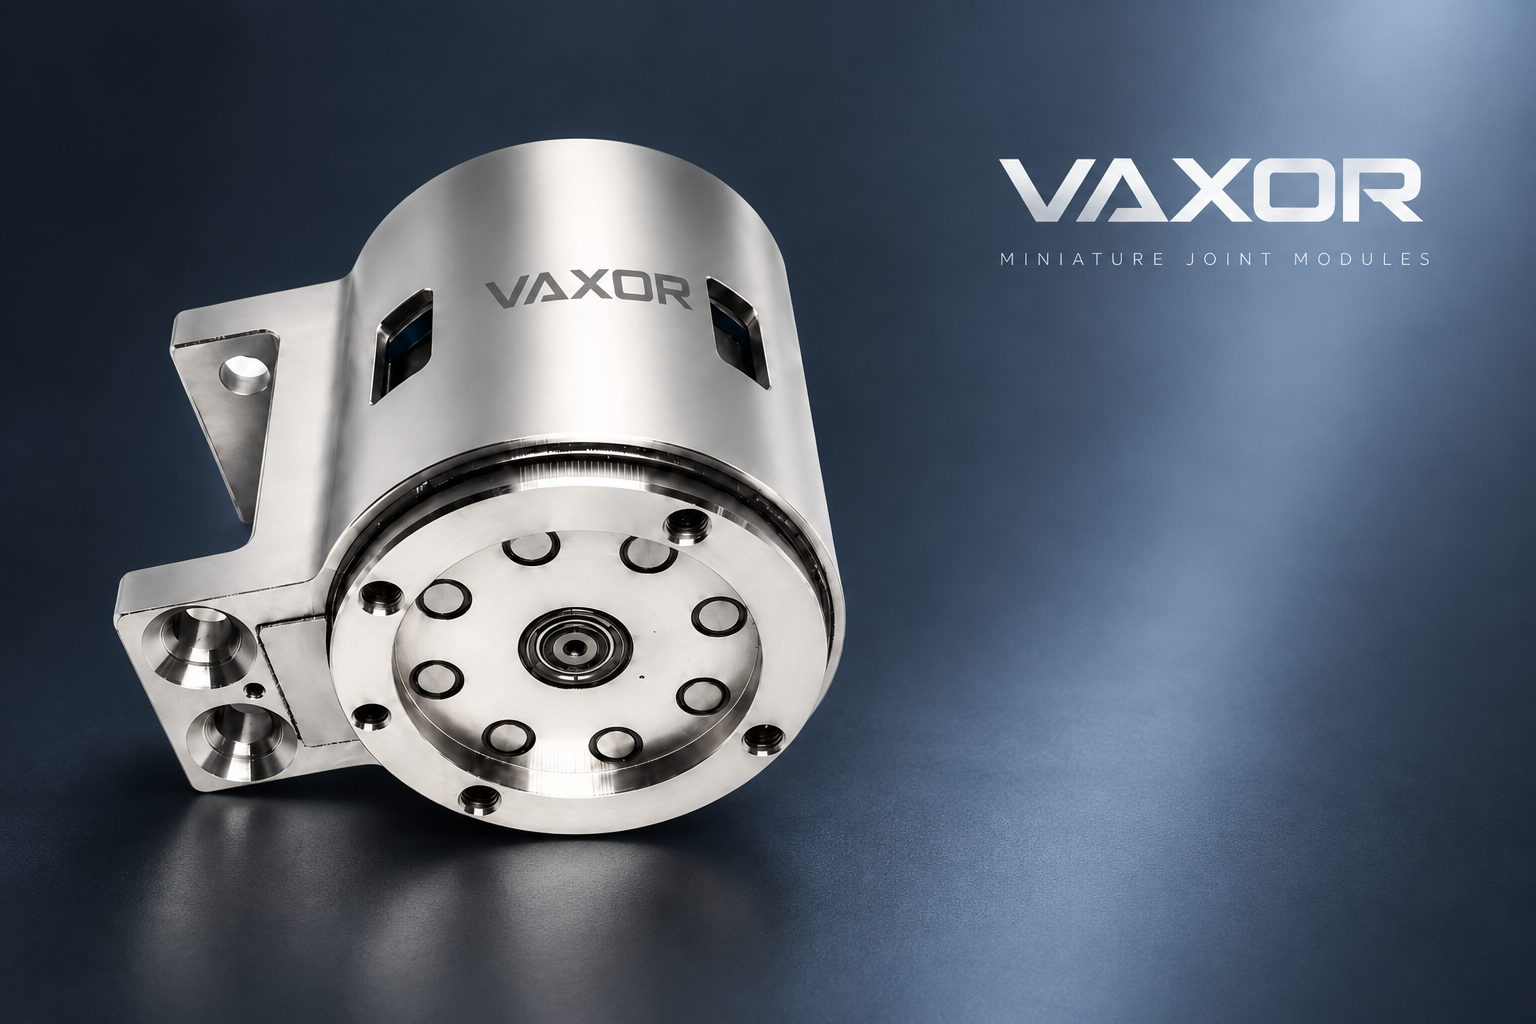
VAXOR's technology platform integrates axial flux motors, micro cycloidal gear reducers, and non-contact absolute magnetic encoders. Key technical metrics include:
- Phase imbalance controlled within 5% for ultra-micro motors
- Actuator diameters ranging from Φ16mm to Φ30mm
- Gear efficiency reaching up to 75% for specific modules
- Backlash as low as 15–20 Arcmin
These specifications are achieved through a modular design architecture and optimized electromagnetic design for brushless and coreless systems, allowing medical robotics engineers to select the appropriate actuator diameter and gear ratio for their specific torque and footprint requirements.
Micro Joint Actuator Modules
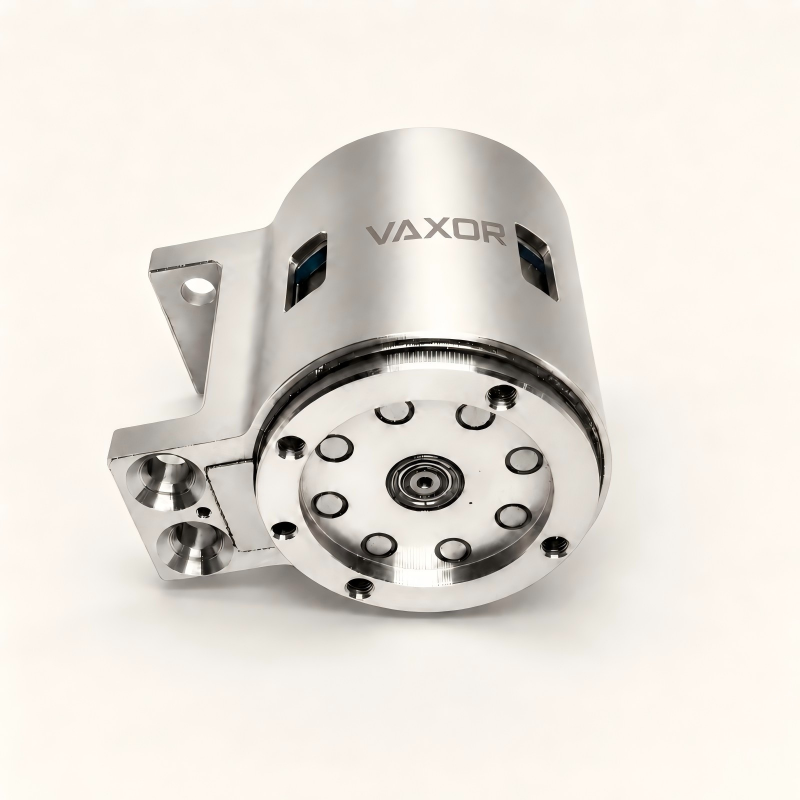
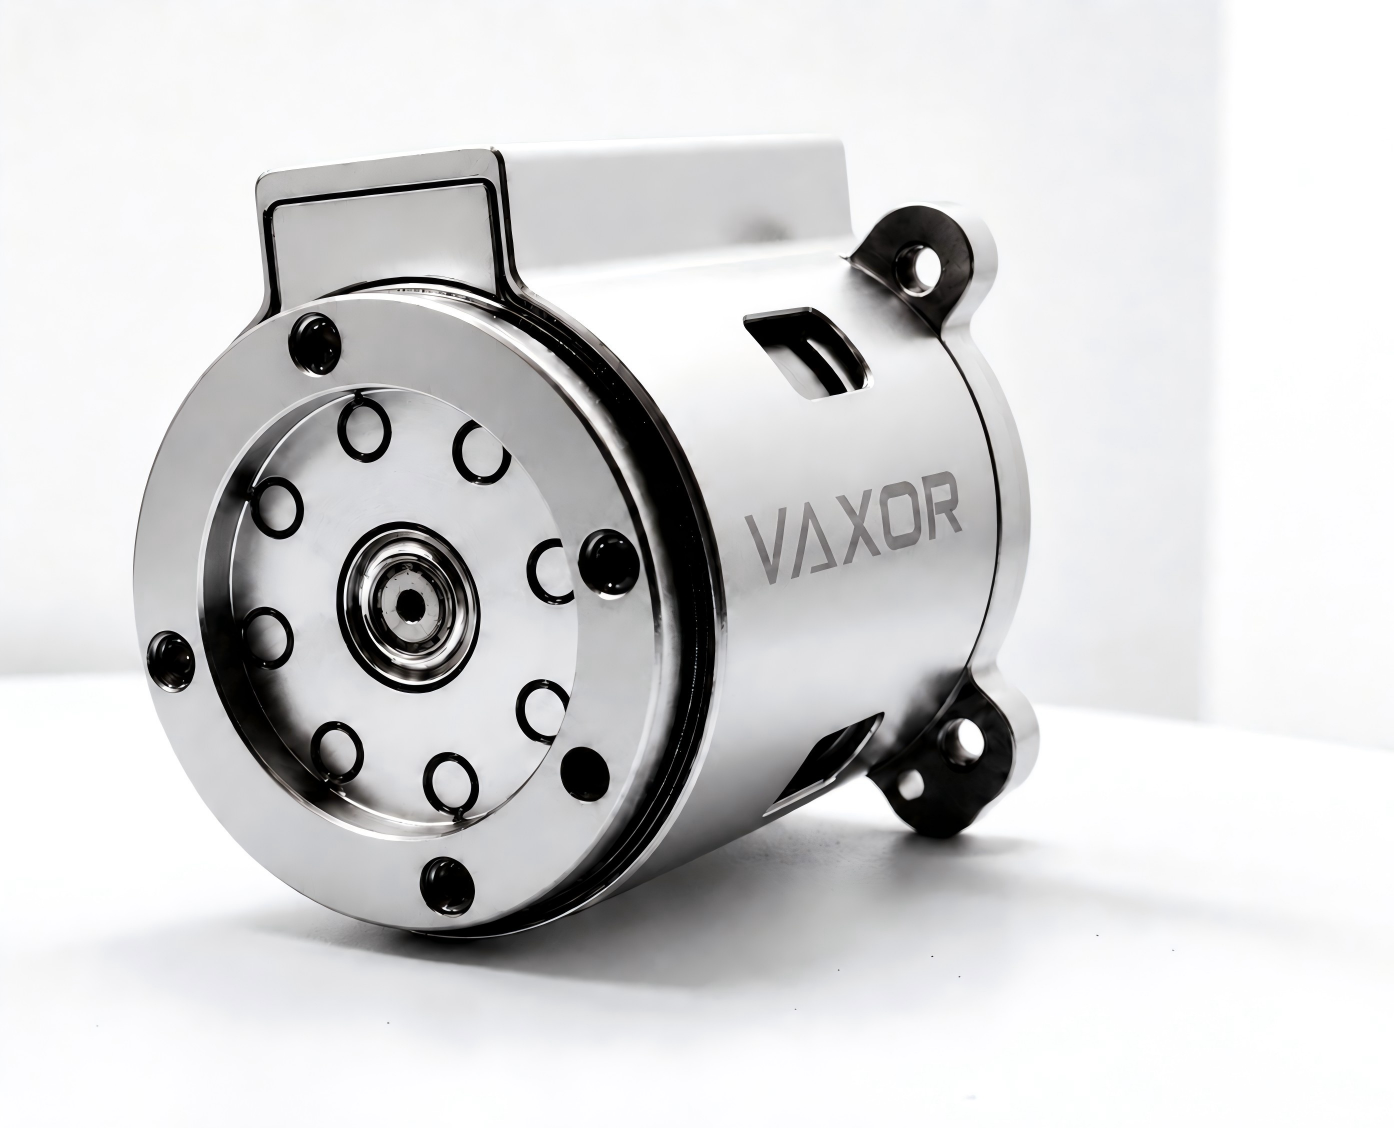
VAXOR's Micro Joint Actuator Modules product line is positioned for precision actuation in dexterous robotic hands, highly integrated robots, and mechanical motion control—applications directly relevant to medical device development. The product range includes:
-
Φ16mm Micro Joint Module (X16S/X16L): Weighing as little as 24.3g (S-version) or 26.1g (L-version), this module delivers continuous stalling torque greater than 7.1 mNm and stalling torque (max) greater than 16.5 mNm. It offers integrated gear reduction ratios of 30, 40, and 50, along with an absolute magnetic encoder for precise position feedback and SPI communication for low-latency control response.
-
Φ20mm Micro Joint Module (X20S/X20L): Designed for medium-load precision actuation, this module provides continuous stalling torque greater than 17.2 mNm and stalling torque (max) greater than 35.3 mNm. It supports 12V/24V/48V operations and offers multi-ratio gearbox options of 15, 30, and 50, reaching up to 450 mNm of stalling torque at ratio 50.
-
Φ25mm Micro Joint Module (X25S-UZ/X25S-BZ): Built for high-torque applications in industrial and medical robotics, this module uses the CAN FD protocol for robust communication and delivers continuous stalling torque up to 1150 mNm at ratio 50, with mechanical strength limits reaching 1800 mNm (initial torque, cold state). Backlash is reduced to 15 Arcmin for high motion accuracy.
-
Φ30mm Micro Joint Module (X30S-UZ/X30S-BZ): The premium option in the line, delivering continuous stalling torque up to 1500 mNm at ratio 50 and gear efficiency up to 75% at ratio 30. It supports CAN FD integration for complex multi-joint network architectures and features a total inertia of 30.4 gcm² for stability during high-load motion.
Ultra-Micro Brushless And Coreless Motors
For applications requiring even smaller form factors, VAXOR's G04P/G05P/G06P Series of ultra-micro brushless and coreless motors is optimized for medical robots, drones, and wearables. These motors address the challenge of high cost and low yield in sub-6mm motor production. Key specifications include ultra-lightweight construction ranging from 1.7g to 3.75g, no-load speeds from 55,000 to 63,000 RPM, thermal resistance supporting chassis temperatures up to 145°C, and terminal resistance as low as 1.6Ω for improved electrical efficiency. The phase imbalance within 5% directly supports yield optimization, reducing costs and improving reliability—an important consideration for medical device manufacturers evaluating component sourcing.
Platform Compatibility And Integration Support
VAXOR's actuators and motors are designed with integration in mind. The platform supports 12V, 24V, and 48V DC bus systems, and communication is handled through SPI or CAN FD protocols. Physical integration is standardized through an FPC 7PIN interface (0.5mm pitch) supporting VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration) connections. This standardization simplifies the process of embedding VAXOR components into robotic limbs and medical device assemblies.
VAXOR's service model combines hardware provision with technical integration support. The company provides detailed technical specifications and test data for its electric drive assemblies, covering torque, speed, and thermal performance parameters, so that medical device developers can verify suitability before deployment.
Demonstrated Application In Medical And Related Fields
VAXOR's components have been applied across several relevant use cases. In micro pump systems, G05P ultra-micro motors operating at 55,000 RPM have been employed to drive fluid transmission in medical and consumer applications, supporting low-cost and high-power-density outcomes. In robotic dexterous hands, X16 and X20 modules have been utilized to achieve high-integration mechanical motion control, enabling human-like finger dexterity—a capability relevant to minimally invasive surgical instrumentation. In photonics, ultra-micro brushless motors have been applied for precision positioning in optical instruments, benefiting from the phase imbalance control within 5% for stable performance.
Industry Coverage
VAXOR's industry coverage extends across robotics (including bionic systems and dexterous hands), medical devices, industrial automation, consumer electronics, aerospace (micro drones), fluid transmission (micro pumps), and photonics (optical instruments). Its customer base includes robot manufacturers, medical device developers, industrial system integrators, and wearable technology firms.
Business Model
VAXOR follows a product-based pricing approach for its standardized modules across the X16, X20, X25, and X30 series. Delivery is structured around hardware integration using standardized FPC 7PIN interfaces or CAN FD/SPI communication protocols, with after-sales support available for technical inquiries regarding product specifications and operational parameter ranges.
For medical robotics developers seeking a high torque density actuator solution, VAXOR's combination of axial flux motor design, micro cycloidal gear reduction, and non-contact magnetic encoder integration offers a documented, parameter-backed foundation for building compact, precise, and reliable robotic systems.
www.vaxor-motor.com
Suzhou Vaxor-motor CO.,LTD.